BalaKolanu
ROBOTICS ENGINEER
01
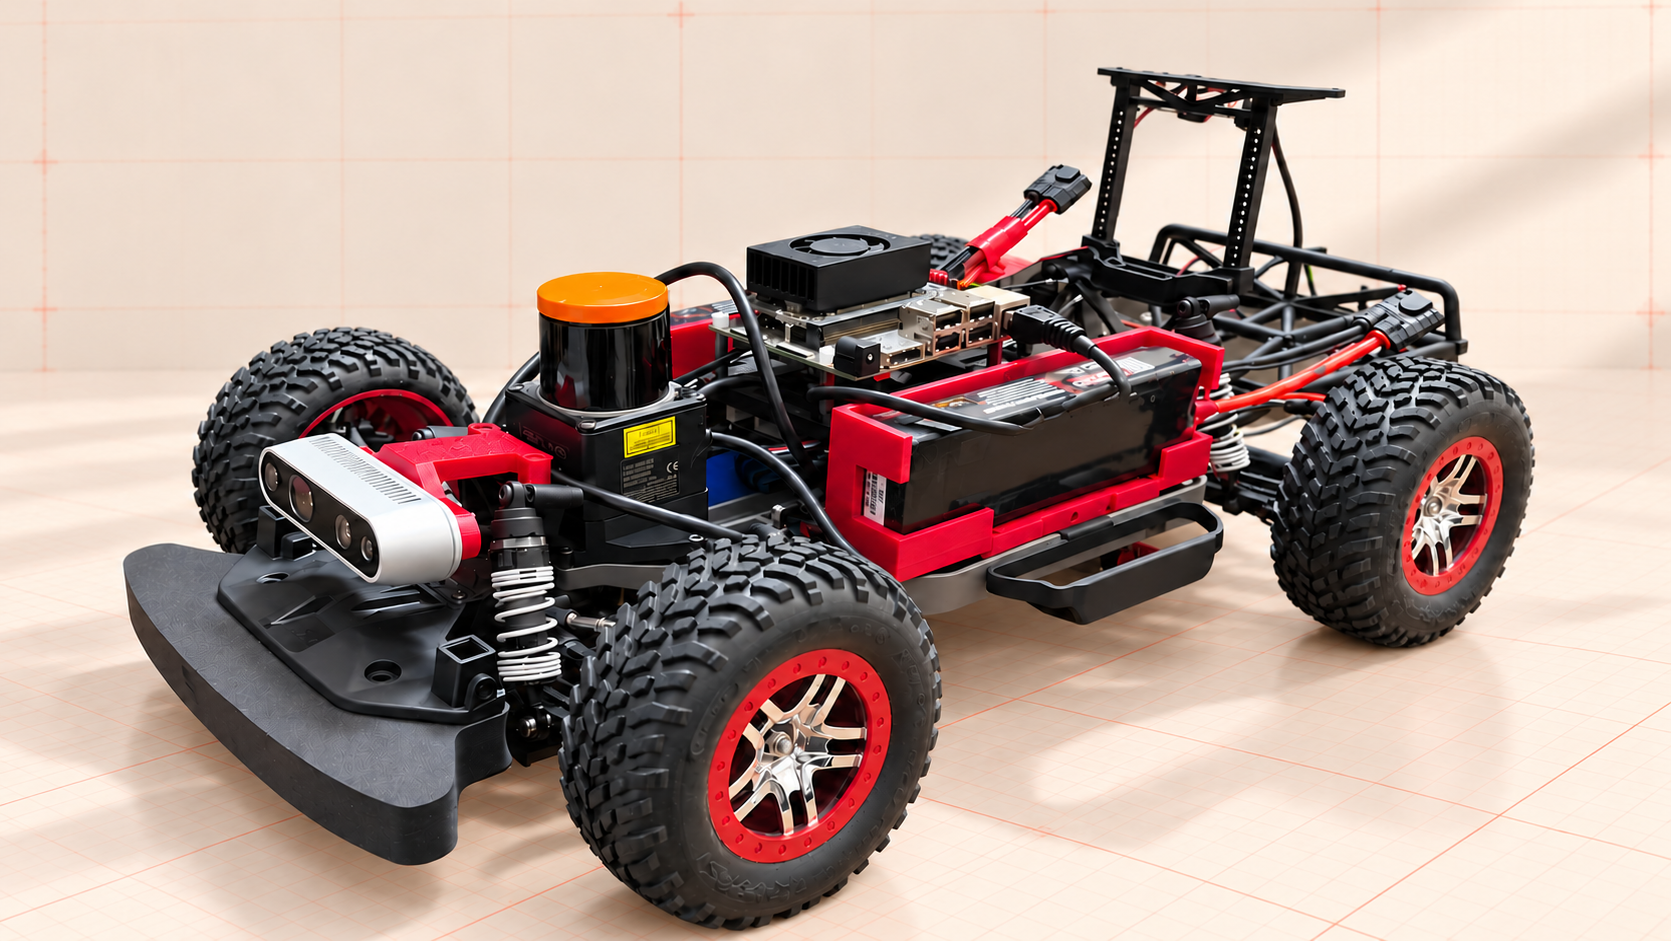
F1tenth
Autonomous racing at 1/10th scale, from perception through planning and control.
View project ↗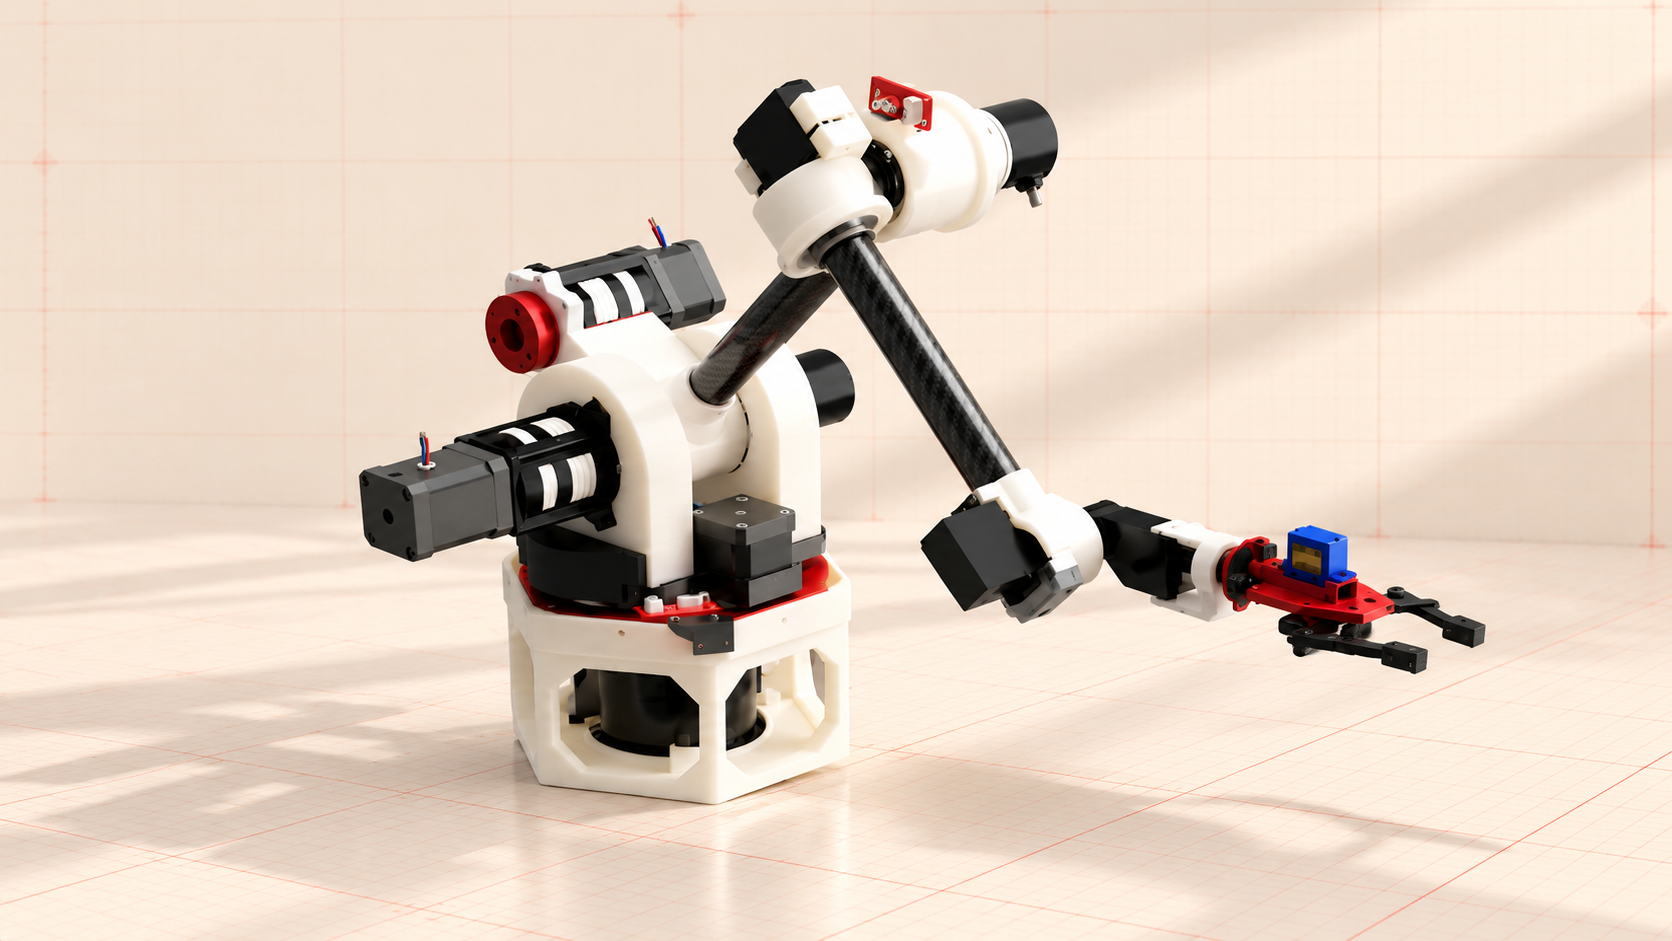
02
Cranker
A six-axis robotic manipulator exploring compliant mechanisms, embedded control, and robust motion.
View project ↗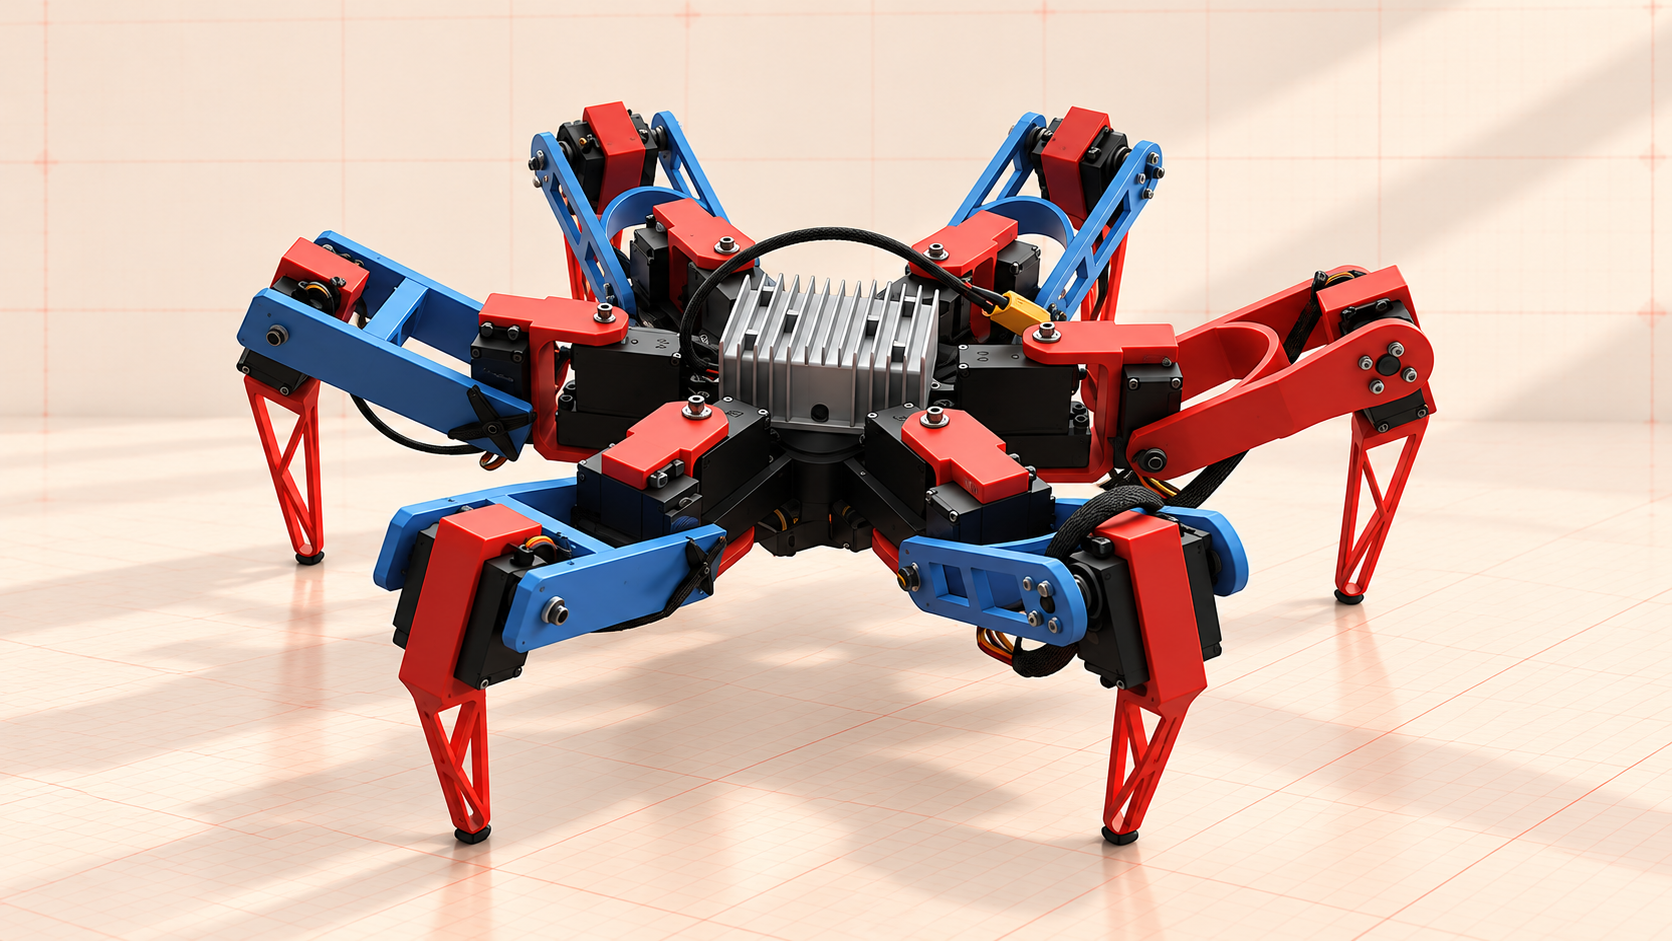
03
Spidey
A hexapod platform focused on agile locomotion, stabilization, and adaptable movement.
View project ↗ABOUT
I am a robotics engineer with a Master’s degree in Robotics from Purdue University. I have been building and studying robots for years, working across mechanical design, electrical systems, embedded firmware, ROS2, perception, localization, motion planning, control, and kinematics. I enjoy taking a robot from a blank page to a working system by designing the hardware, writing the firmware, and developing the software that brings it to life.